Robotic Learning from Human
Reusable robot skills from human instructions, demonstrations and interaction history.
ROBOT LEARNING · MULTIMODAL INTERACTION · MANIPULATION
I'm Tan Runjia, also known as Armine, a PhD candidate at NTU working to bring robot learning from industry into everyday life. I am supervised by Lyu Chen.
Third-year PhD · Nanyang Technological University · Singapore
EXPLORE MY WORK ⟶
Reusable robot skills from human instructions, demonstrations and interaction history.
Aligning language, gestures and visual perception to understand human intent.
Connecting perception, planning and control for precise, practical robot systems.
 01
Research
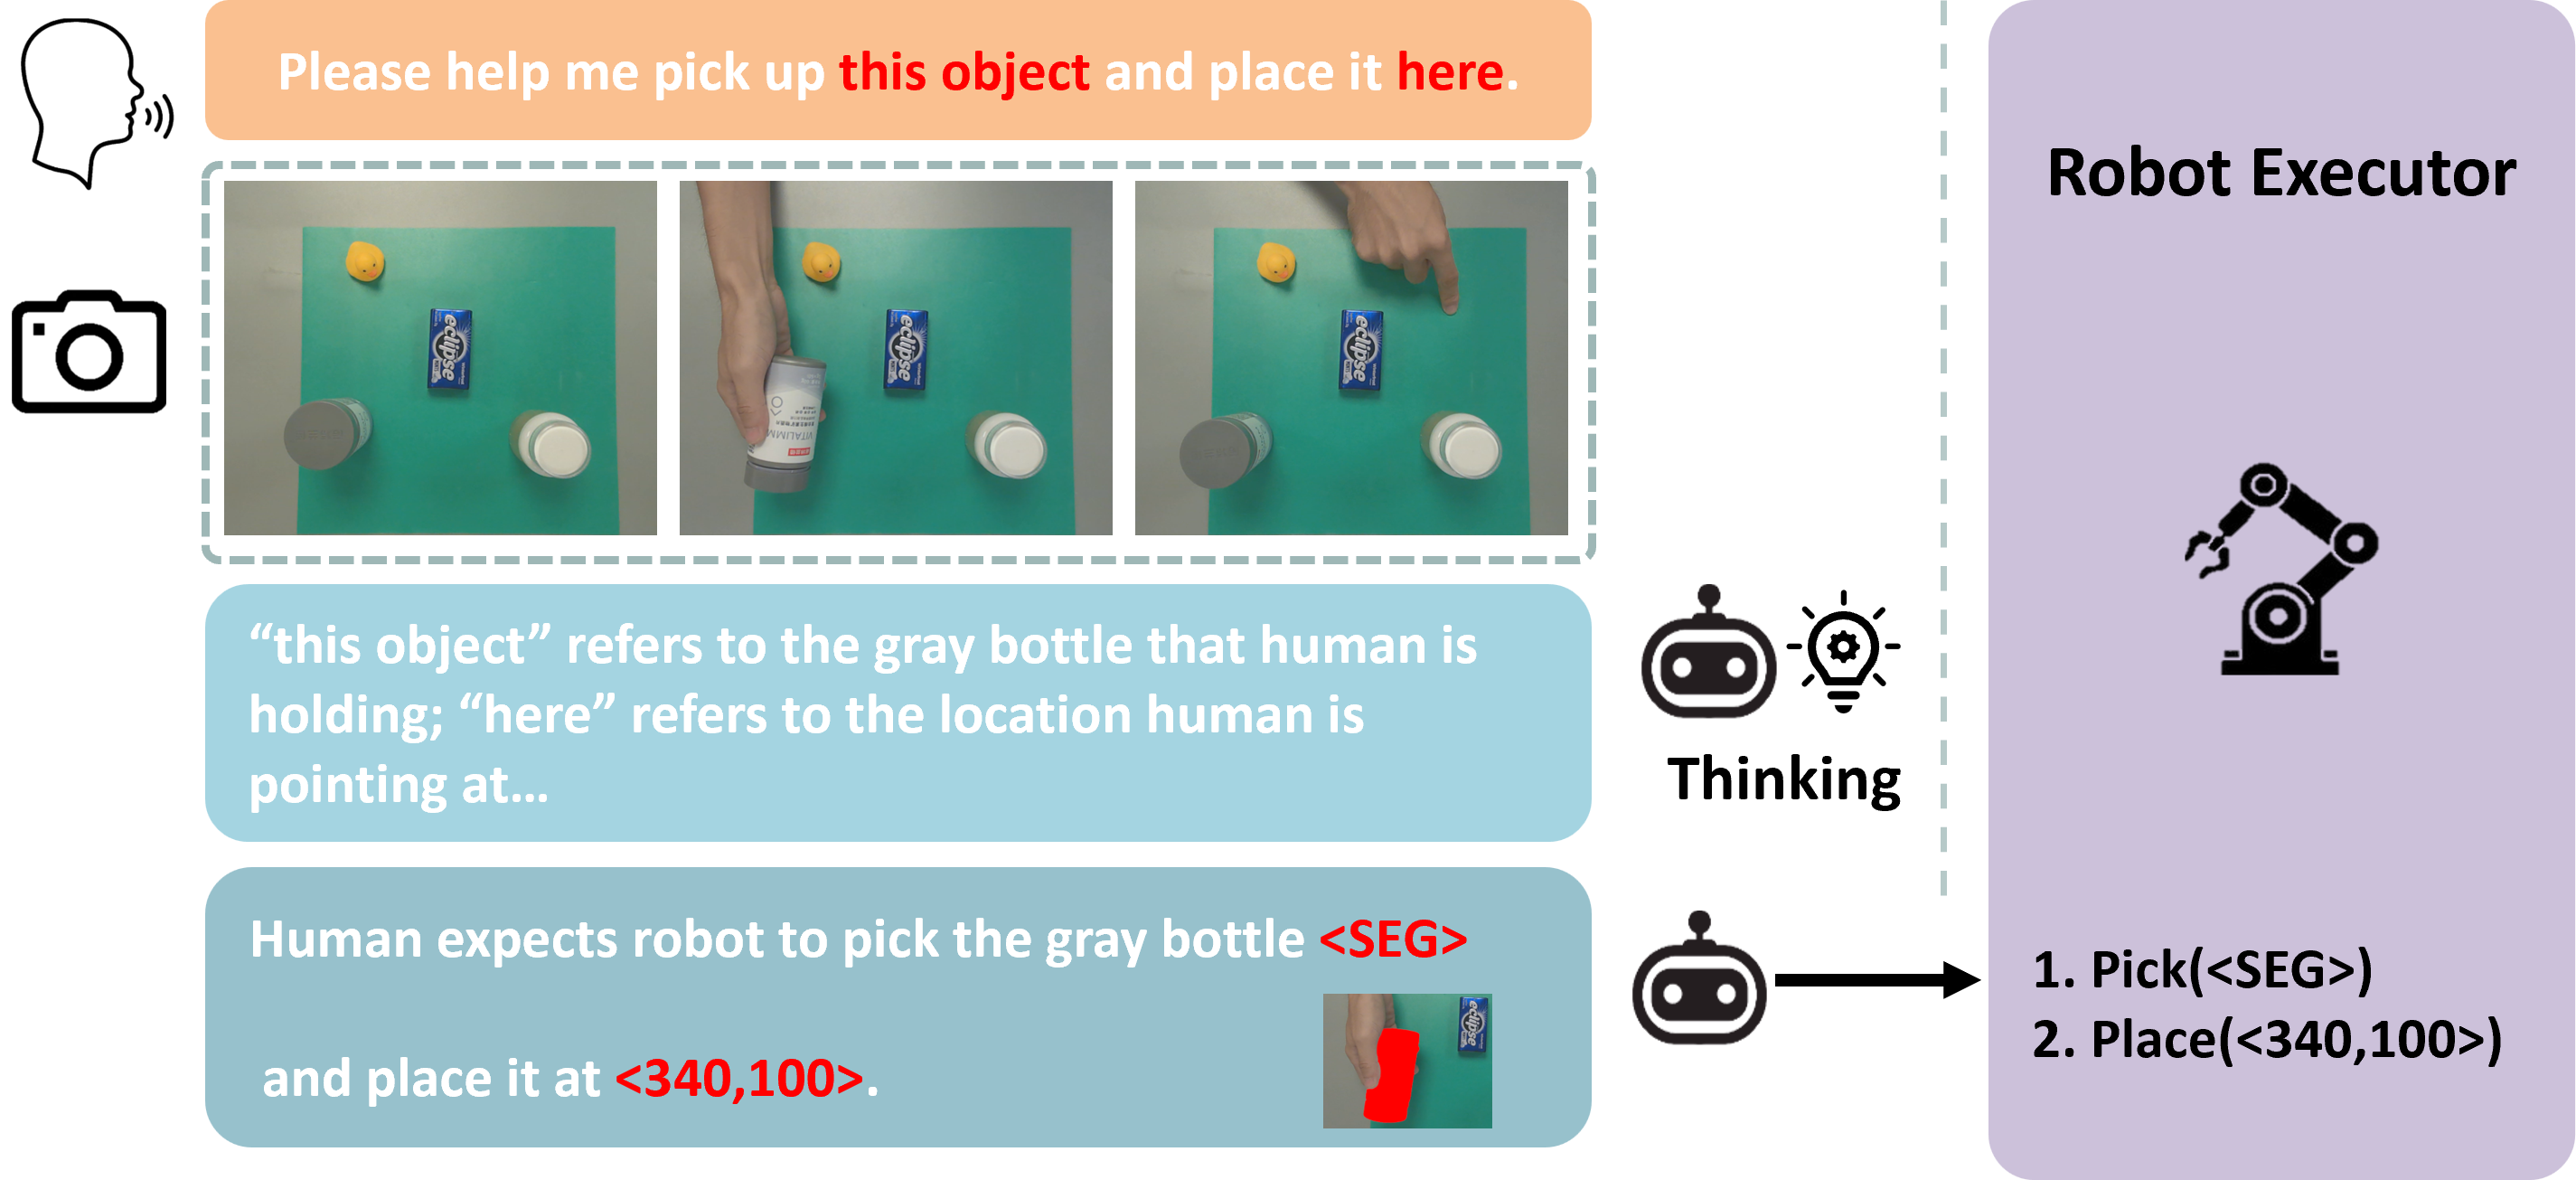
Grounding “this” and “here” in speech and gestures, so robots can identify what to move and where it belongs.
 02Official image · Intrinsic
Industry collaboration
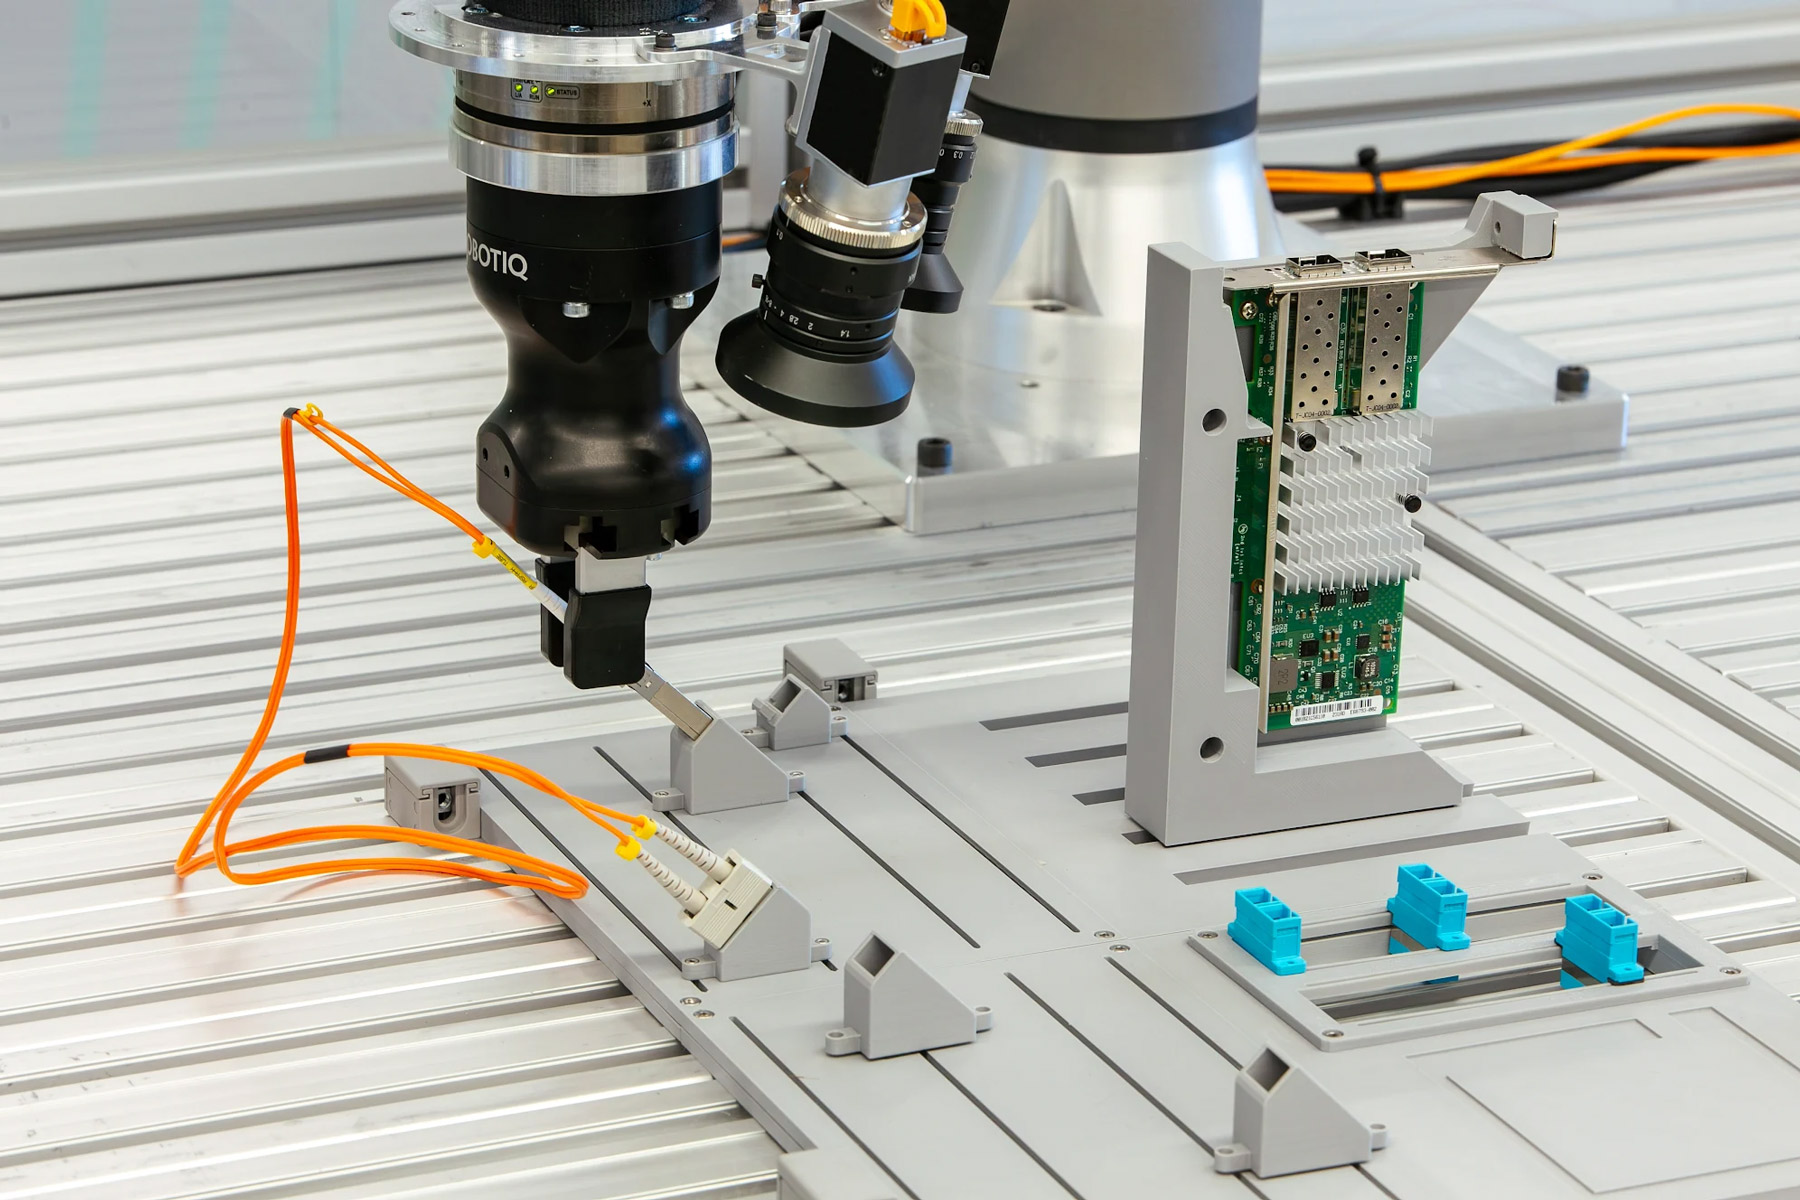
Robotic cable insertion through visual registration and force feedback, in collaboration with Desay SV Singapore.
 03
Research & engineering
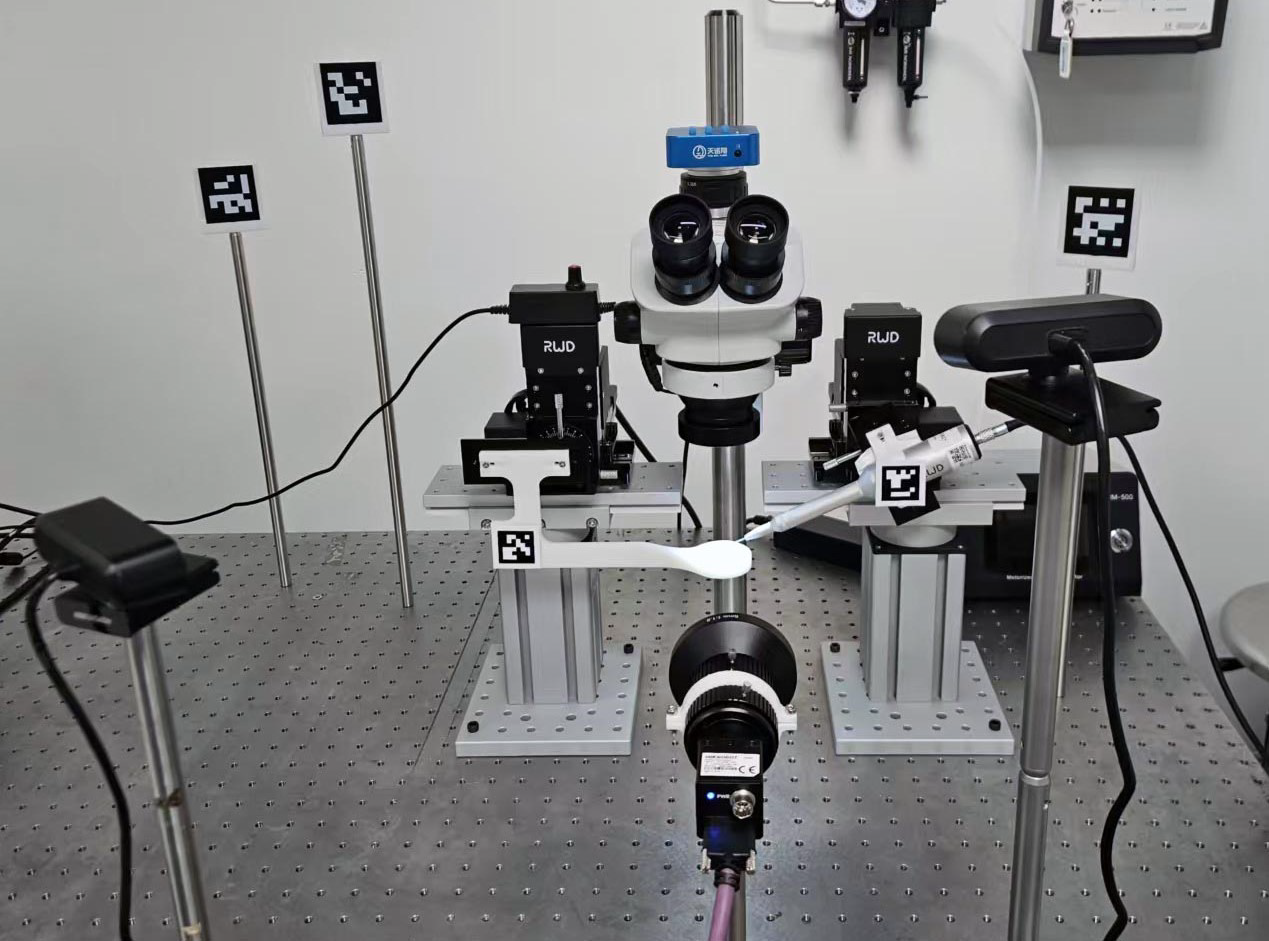
A hardware-agnostic vision-servoed system for automated, precise injection of implantable microdevices.
Research
Grounding “this” and “here” in speech and gestures, so robots can identify what to move and where it belongs.
Industry collaboration
Robotic cable insertion through visual registration and force feedback, in collaboration with Desay SV Singapore.
Research & engineering
A hardware-agnostic vision-servoed system for automated, precise injection of implantable microdevices.
CIS-RAM 2026
ICRA 2026
Journal of Manufacturing Systems · 82, 1213–1226 · 2025
CIS-RAM 2024 · 14–19
Best PaperIEEE Robotics and Automation Letters · 7(4), 12451–12458 · 2022
† Equal contribution.
VIEW PUBLICATIONS ⟶I welcome conversations about robot learning, multimodal interaction, and bringing research into practical robotic systems.
Nanyang Technological University · Singapore