DESAY SV SINGAPORE · MATRIXX
Cable Assembly & Contact-Guided Insertion.
Combining visual perception and contact feedback to make robotic connector insertion more reliable.
- Collaboration
- Desay SV Singapore
- Challenge
- Intrinsic AI for Industry Challenge
- Milestone
- MatrixX · Qualification Phase 7th
01 · THE CHALLENGE
Finding a port is only the first step
Cable assembly brings perception and physical interaction into the same task. A robot must locate the connector and its target, approach with the correct orientation, and respond when contact changes the motion. Small alignment errors can become failed insertions.
In collaboration with Desay SV Singapore, our team MatrixX explores how visual registration, contact feedback and learned skills can support this process. The work combines system integration with experiments in connector insertion.
02 · THE APPROACH
See, make contact, and adjust
Locate and align
Visual perception identifies task-board components and estimates the relative geometry needed to approach a connector and port.
Respond to contact
Contact feedback helps distinguish free motion from interaction with the socket, supporting alignment corrections during insertion.
Develop reusable skills
Policy-learning experiments investigate reliable single-end insertion, using demonstration data and feedback during development.
03 · PHASE 1 · JUL 2026
Two-end insertion record
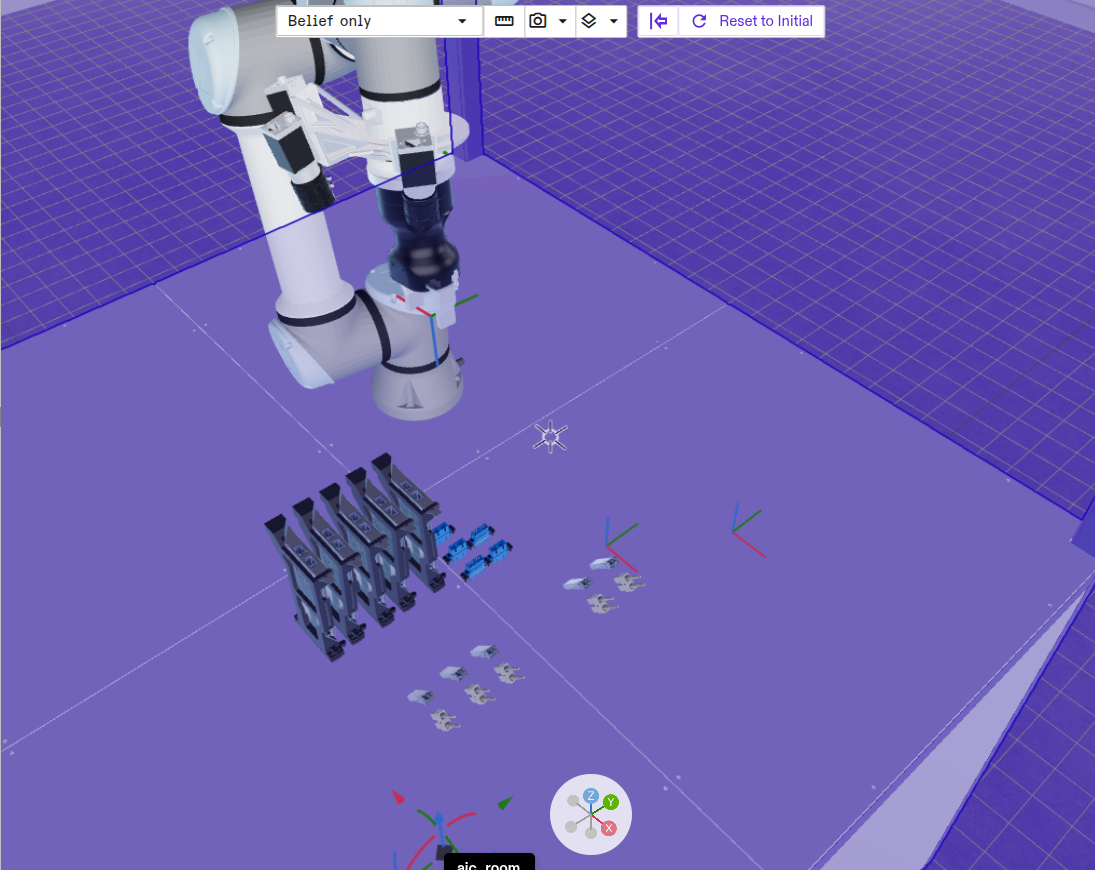
The Phase 1 record follows a two-end cable-insertion task in simulation. The accompanying scene view shows the robot and task-board components used during development.
04 · QUALIFICATION PHASE · 7TH PLACE
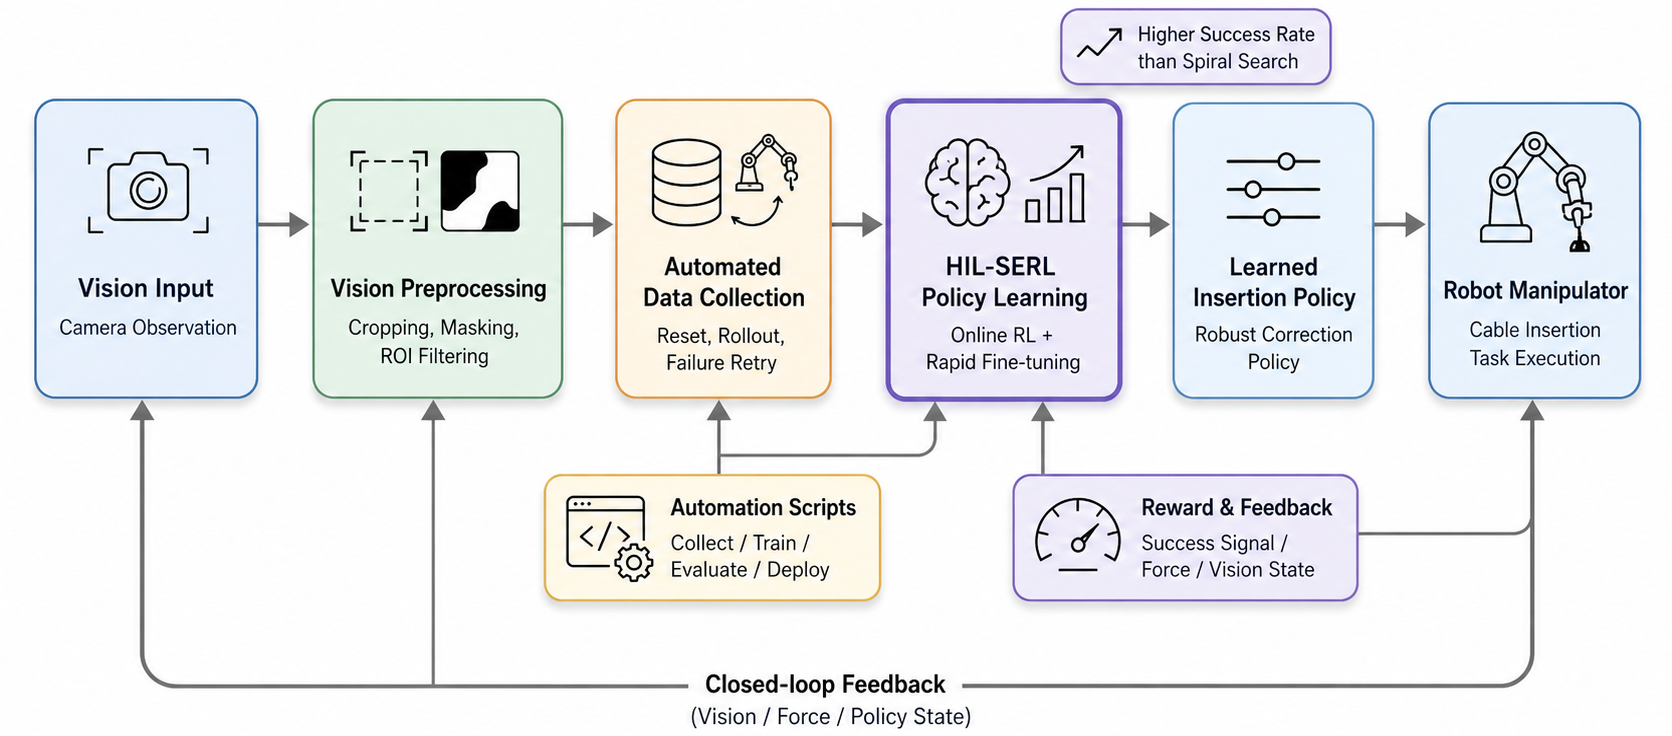
Automated HIL-SERL workflow
MatrixX placed 7th in the Qualification Phase. The workflow brings together visual preprocessing, automated data collection, policy learning and feedback during insertion.
Explore 7 qualification rollouts Different positions on two rails
These examples show individual insertion rollouts at the rail positions labeled in the source recordings.
Rail 0 · −0.030
Rail 0 · 0.000
Rail 0 · +0.030
Rail 0 · +0.055
Rail 1 · −0.050
Rail 1 · −0.030
05 · LABORATORY DEVELOPMENT
From perception to insertion
Selected examples from the 2026 project reports show the components under development. Each demonstration is labeled by its setup and stage.
REAL ROBOT · LABORATORY FIXTURE · JUN 2026
Insertion on a physical arm
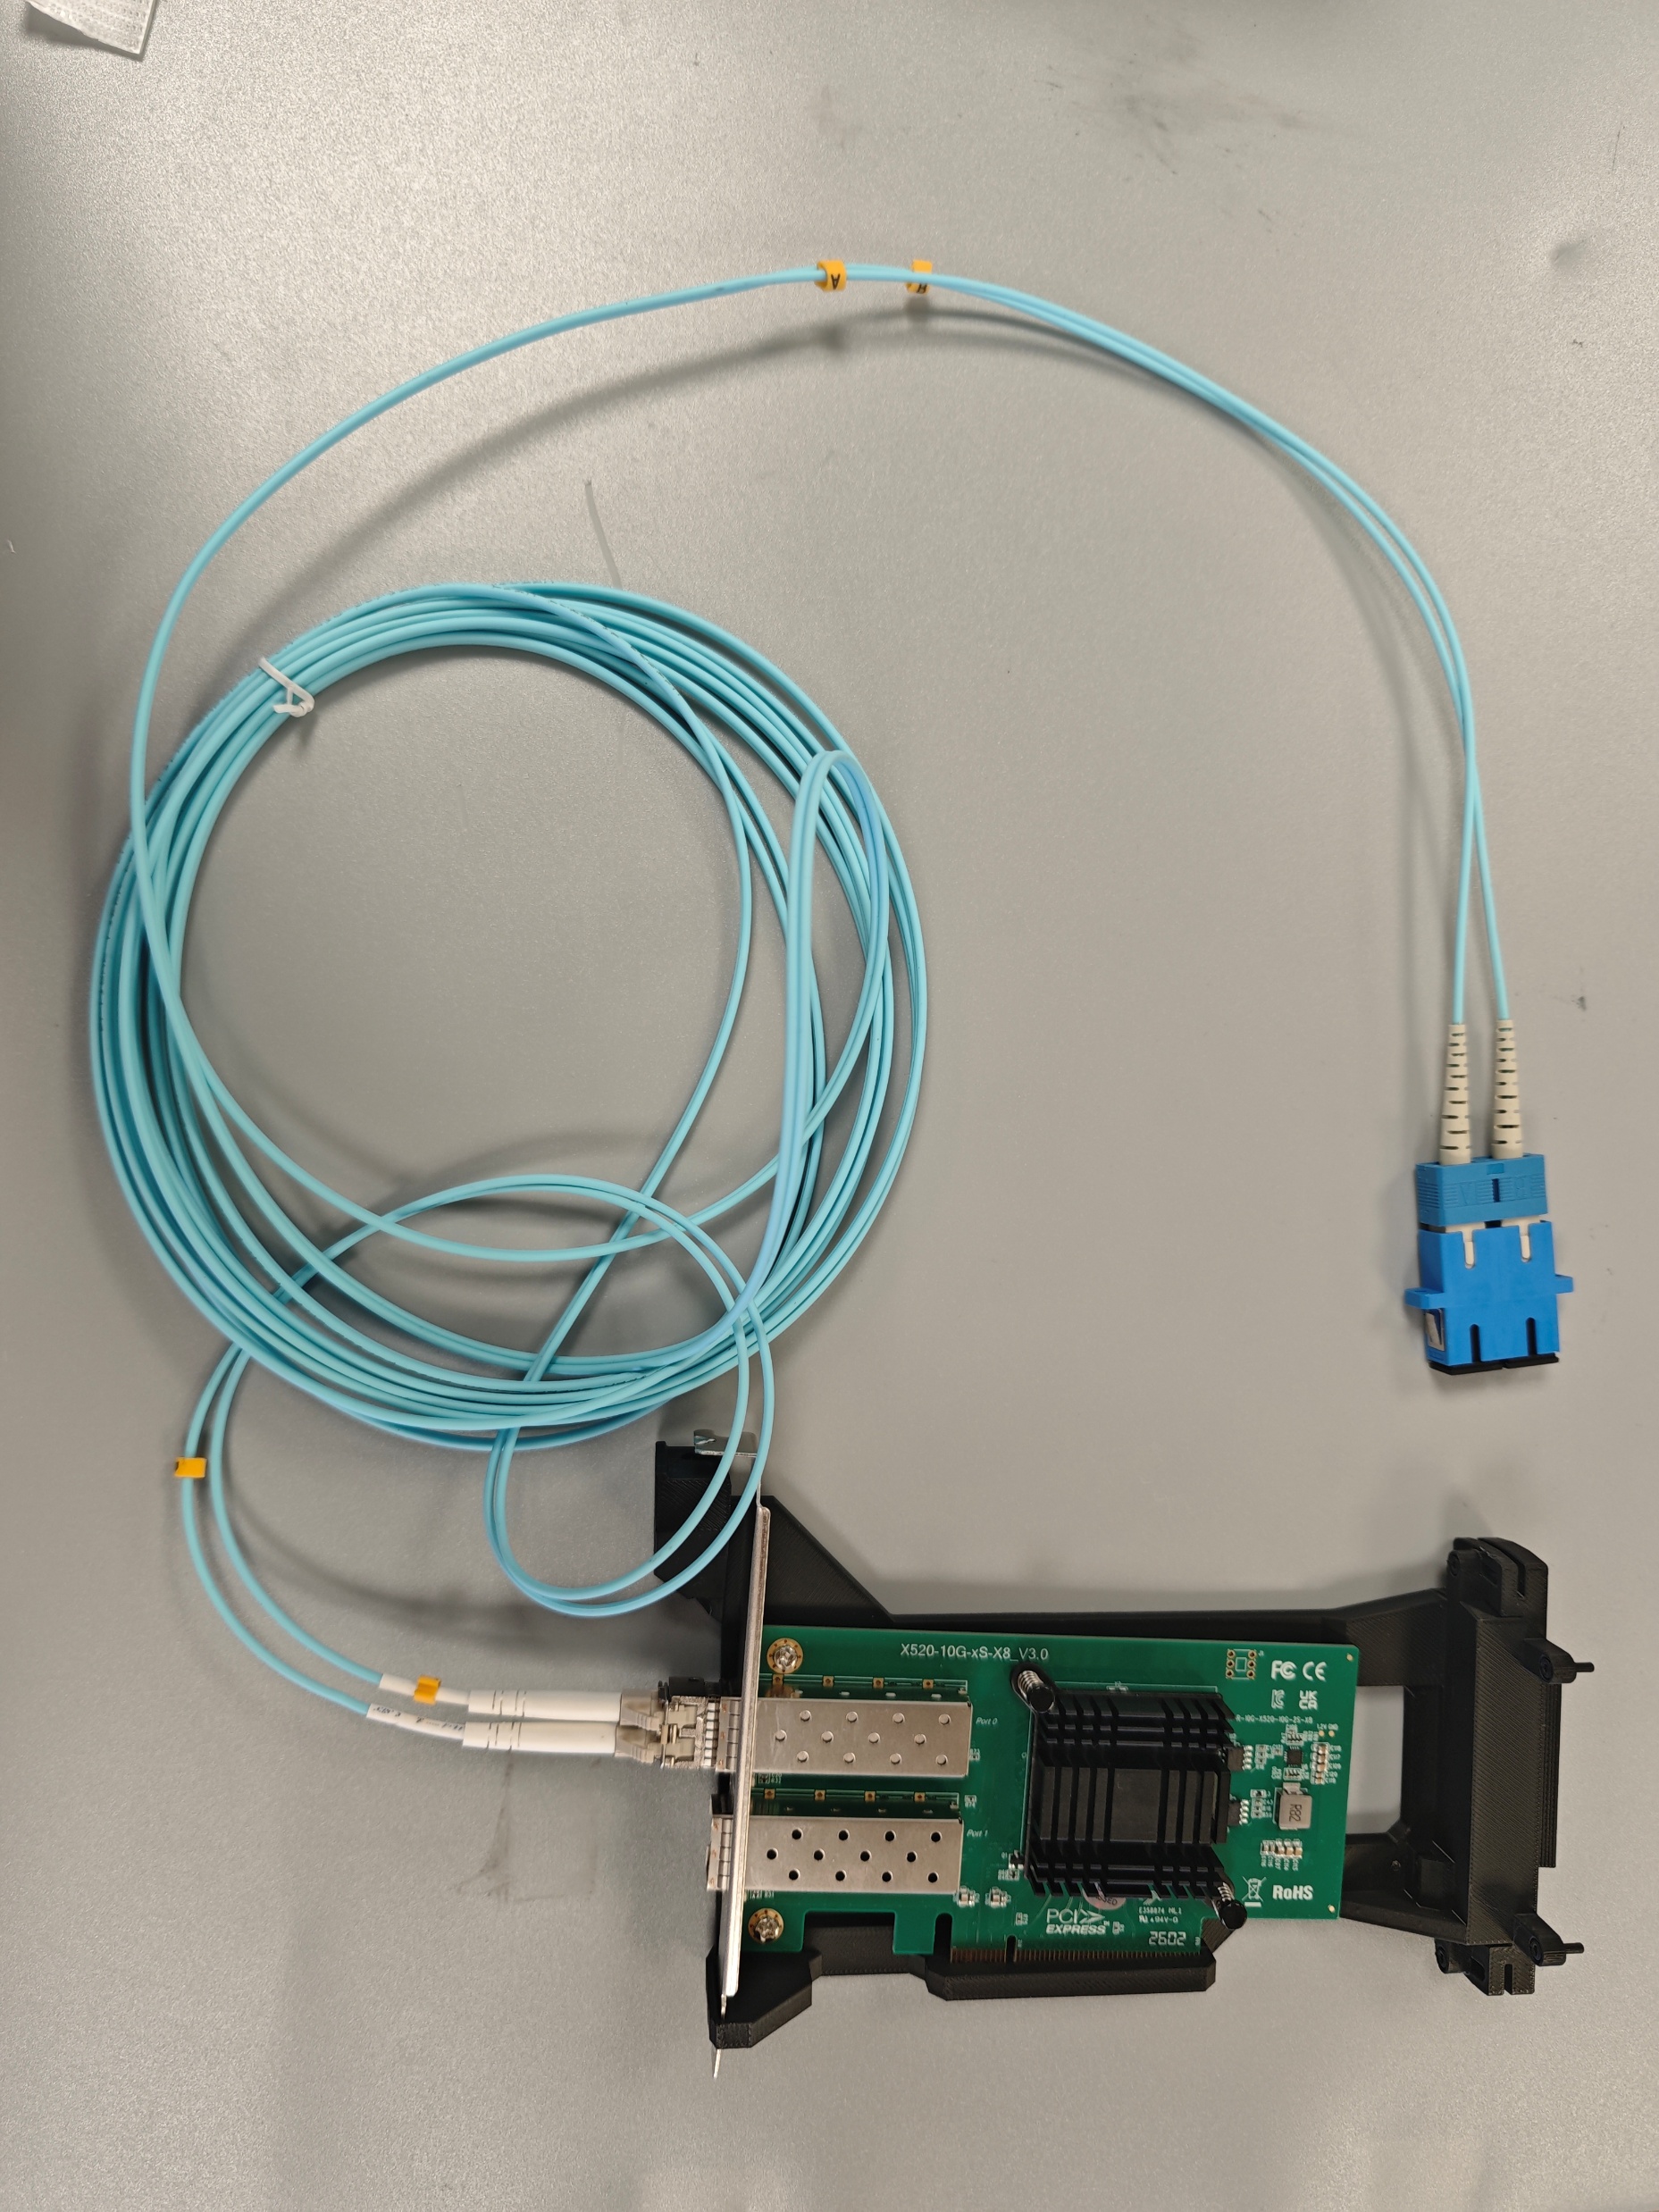
HARDWARE PREPARATION · JUN 2026
SC connectors and NIC hardware
06 · RESEARCH & ENGINEERING
Building reliability one skill at a time
Visual registration
Early iterations focus on recognizing components and connecting image observations with approach poses.
Contact-guided execution
Insertion experiments investigate contact response, alignment errors and the conditions under which a connector seats successfully.
Policy learning
Later reports explore single-end insertion policies and observer-guided learning as a route toward more reusable manipulation skills.
Simulation and physical experiments
The July videos document challenge development in simulation. The June fixture demonstration shows a separate physical setup. Each record keeps its stage and setup visible, while the team continues to develop reliable insertion across a wider range of conditions.
COLLABORATION
MatrixX · AI for Industry Challenge
Our team MatrixX placed 7th in the Qualification Phase of the Intrinsic AI for Industry Challenge. The project continues to connect research in robot learning with the practical demands of industrial assembly.